


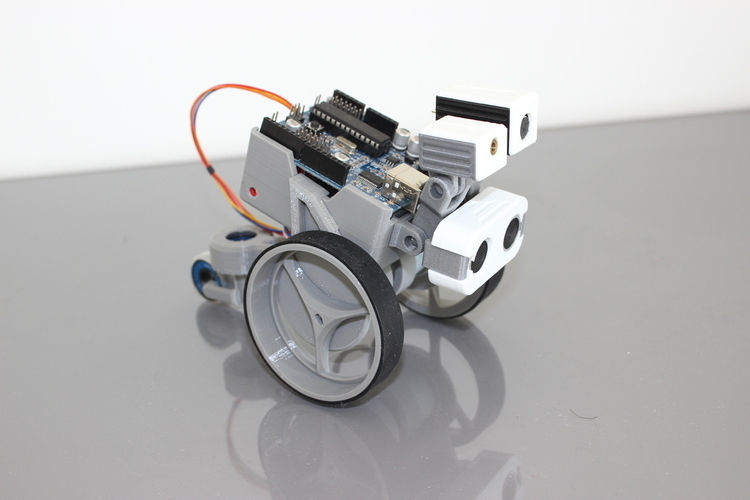
Summary Finally the Rpi version of SMARS is arrived! This model is designed to be an UGV and is a remix of the Zerobot project. To build it you will need the following components:
motor driver
camera
RPi
Booster (optional)
Rechargeable Battery (optional)
SMARS basic version
SMARS 3A batteries Mod
Filaflex tracks (optionals)
For the software, you can follow the tutorial of the original Zerobot: you'll probably have to rotate the camera image, to do this you just have to open the file /etc/rc.local in a text editor and remove the expressions "-vf" and "-hf" from this line: LD_LIBRARY_PATH=/opt/mjpg-streamer/ /opt/mjpg-streamer/mjpg_streamer -i "input_raspicam.so -vf -hf -fps 15 -q 50 -x 640 -y 480" -o "output_http.so -p 9000 -w /opt/mjpg-streamer/www" > /dev/null 2>&1&"
Join us on facebook for updates and software help: Many thanks to Wingman94 for the great software and the amazing idea!
Print Settings Printer: Witbox Supports: Yes Resolution: 0.2 Infill: 20%
Loading prints...
SMARS Zero

Creative Commons Attribution-NoDerivatives
You can download, share, and use commercially, but you cannot change the material in any way or use it to make something new.
 Licensed under CC BY-ND


Loading comments...